
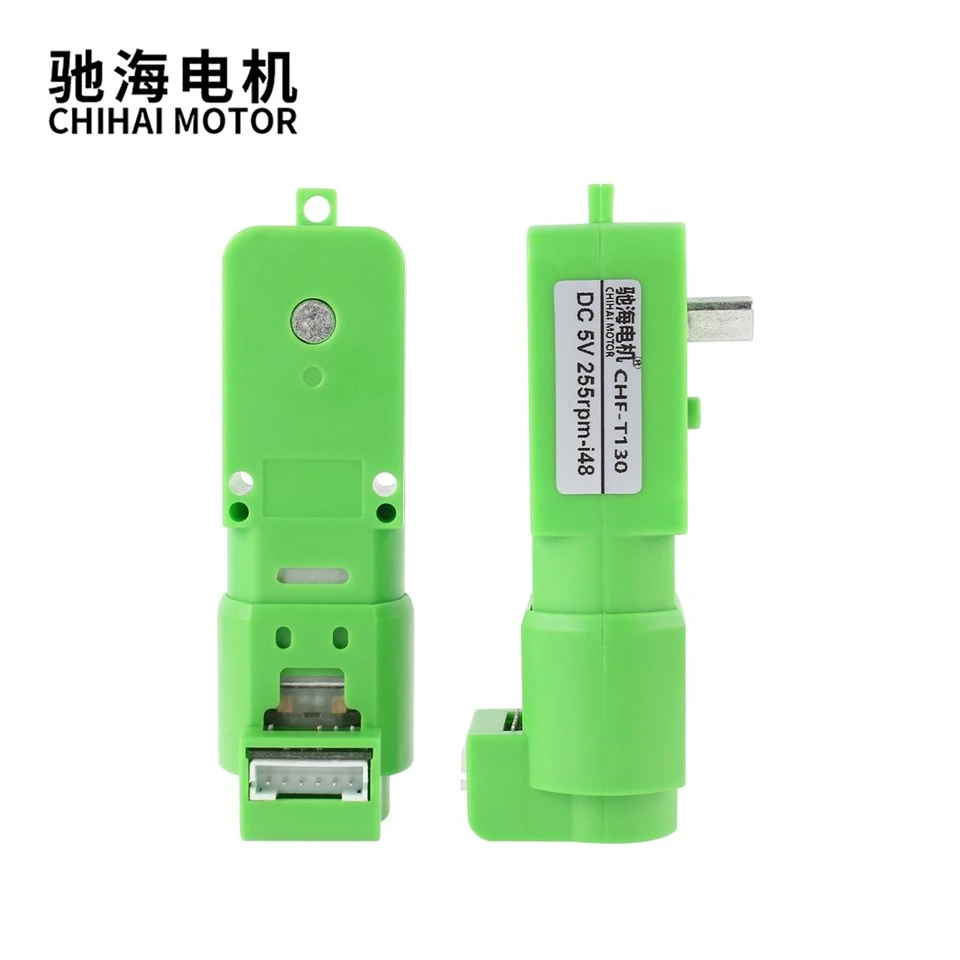
DC Gear Motor With Encoder TT Motor DC5V
Product Description:
| Brand | CHIHAI MOTOR |
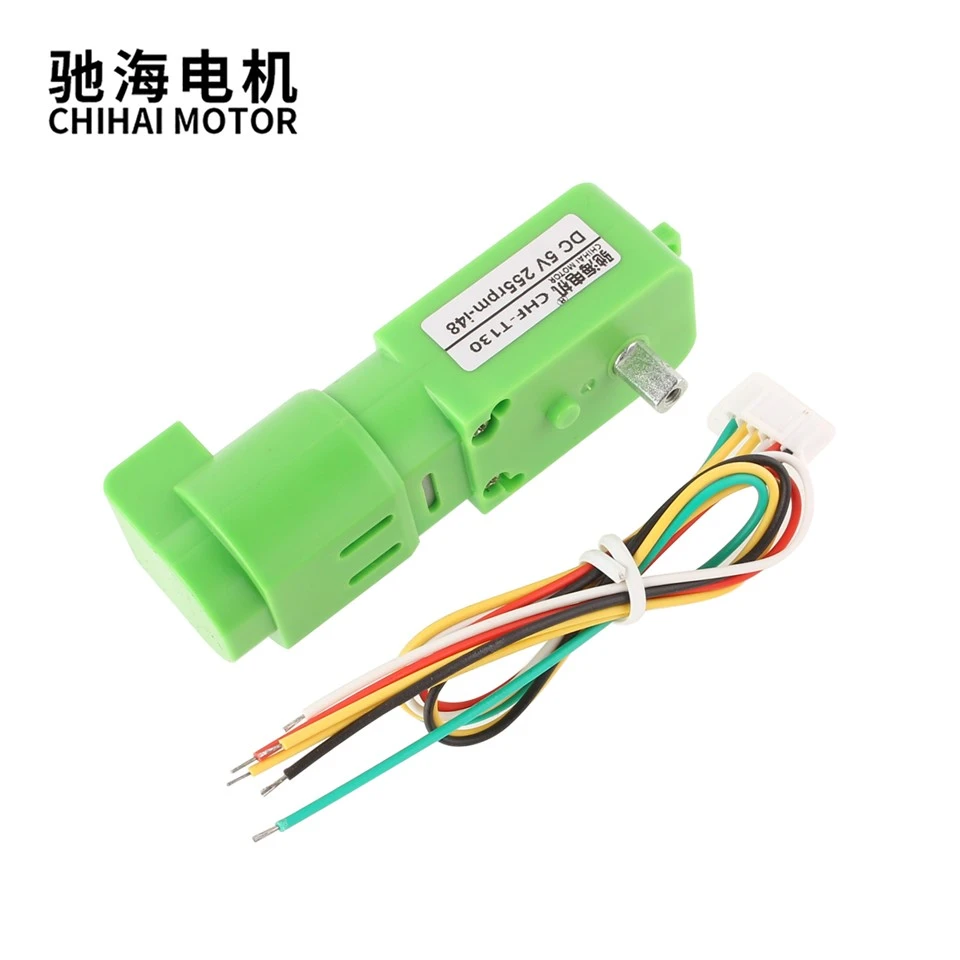
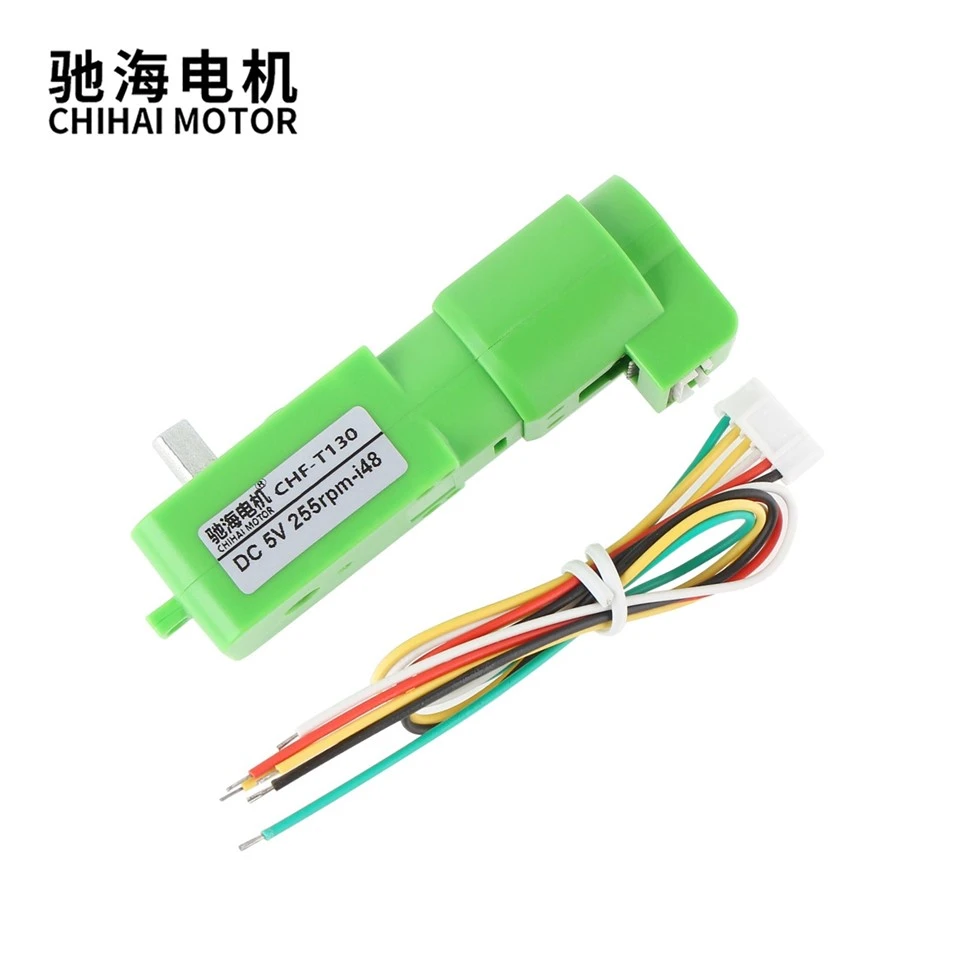
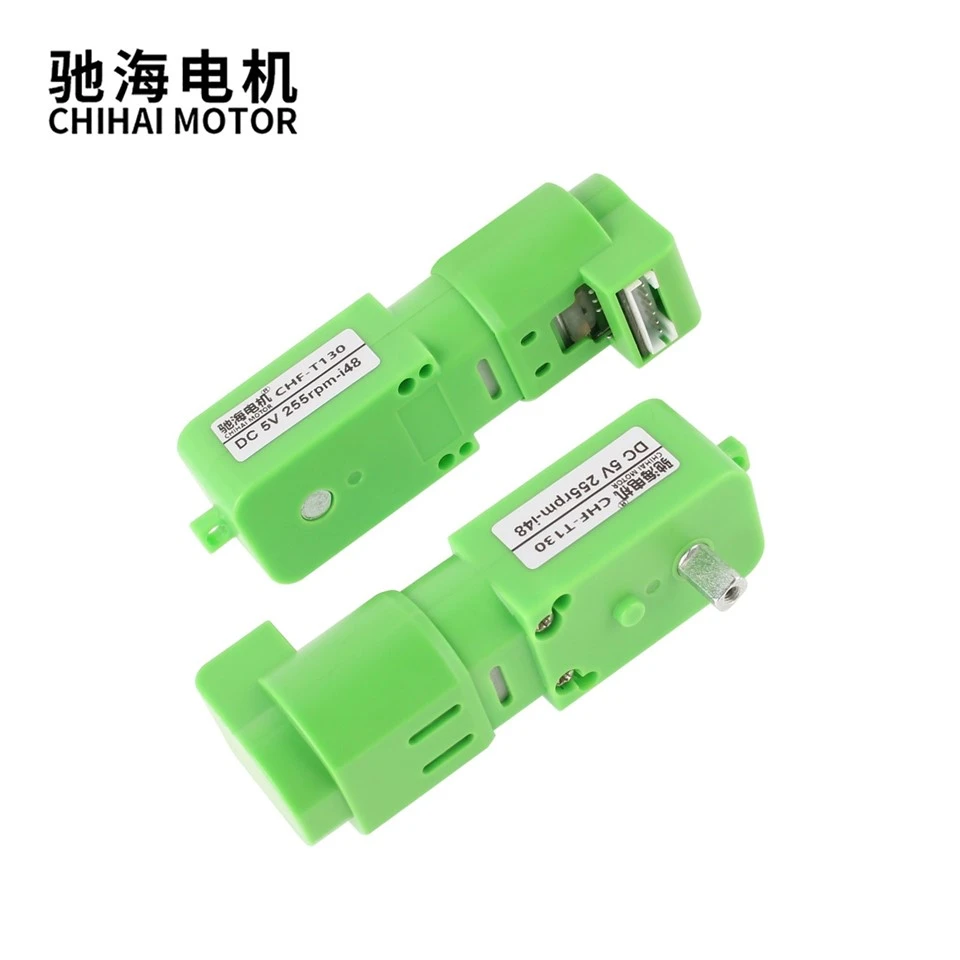
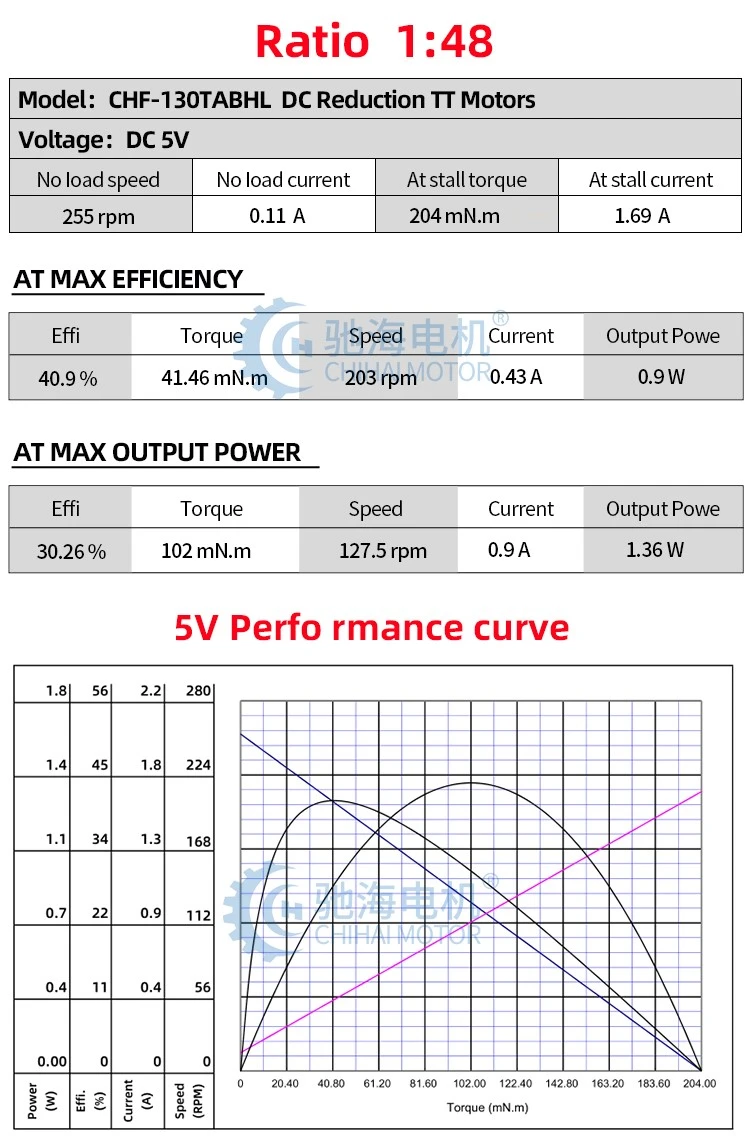
| Product Type | CHF-130T ABHL DC Gear Motor With Encoder TT Motor |
| Shaft Length | 8.5mm |
| Shaft Dianeter | φ 5.5mm |
| Voltage | DC 5V |
| Weight | About 53g |
| reduction ratio | 1: 48,1: 90 |
| Wiring specification | PH2.0-6PIN terminal connector |
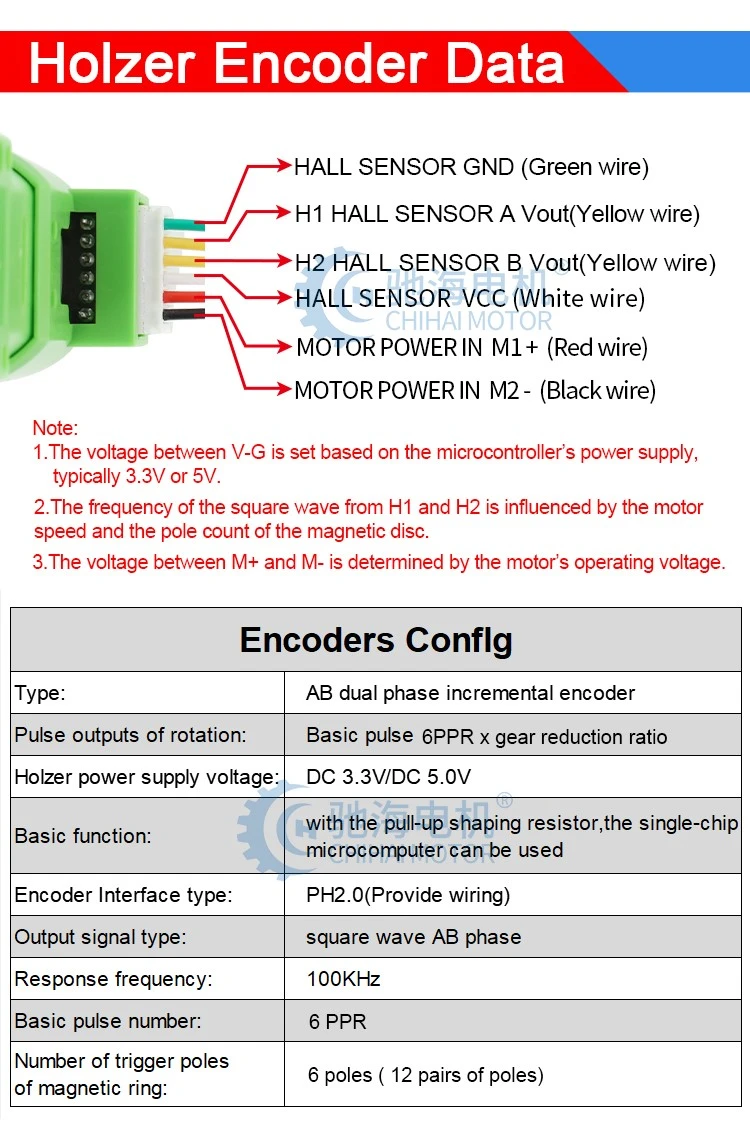
| Encoder Specification | A B dual phase encoder, 6 line basic signal voltage 3.3V or 5.0V |
| Application | There are scientific research electronic products, robot electric body class, bubble gun play Guns, four-wheel drive toys and cars, aircraft toys Vibration products such as electric toy products. |
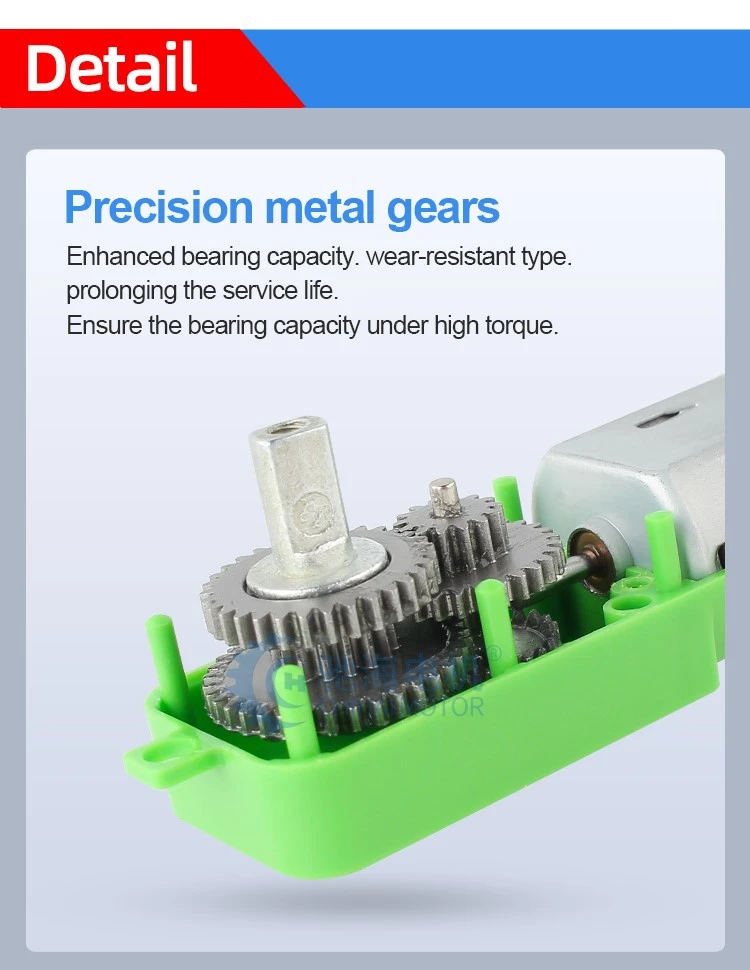
Precision metal gears:
Enhanced bearing capacity. wear-resistant type. prolonging the service life. Ensure the bearing capacity under high torque.
ABS material:
Environmentally friendly and durable without rusting to extend the service life.
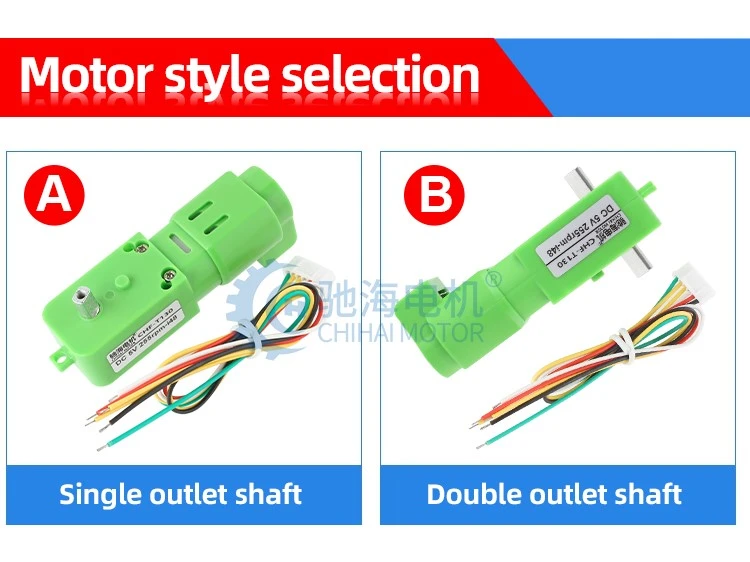
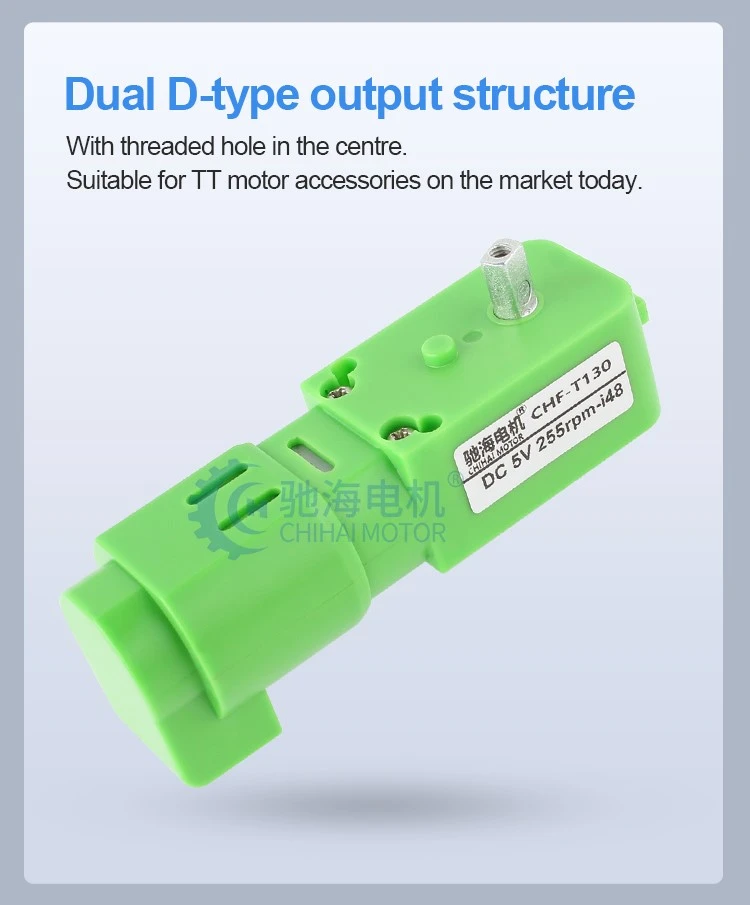
Dual D-type output structure:
With threaded hole in the centre. Suitable for TT motor accessories on the market today.
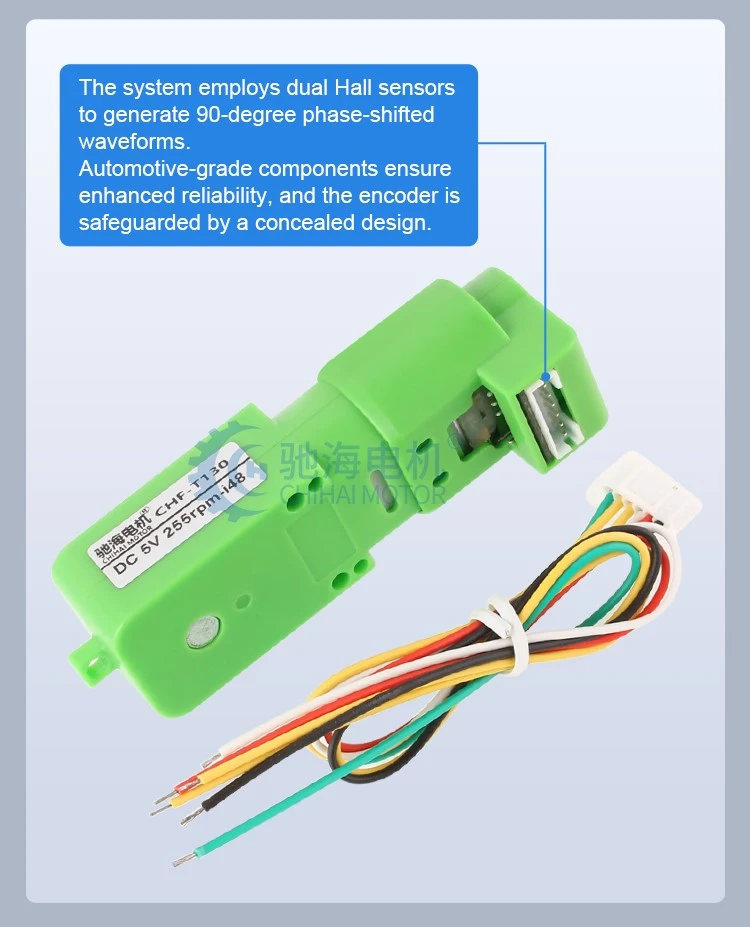
The system employs dual Hall sensors to generate 90-degree phase-shifted waveforms.
Automotive-grade components ensure enhanced reliability, and the encoder is safeguarded by a concealed design.
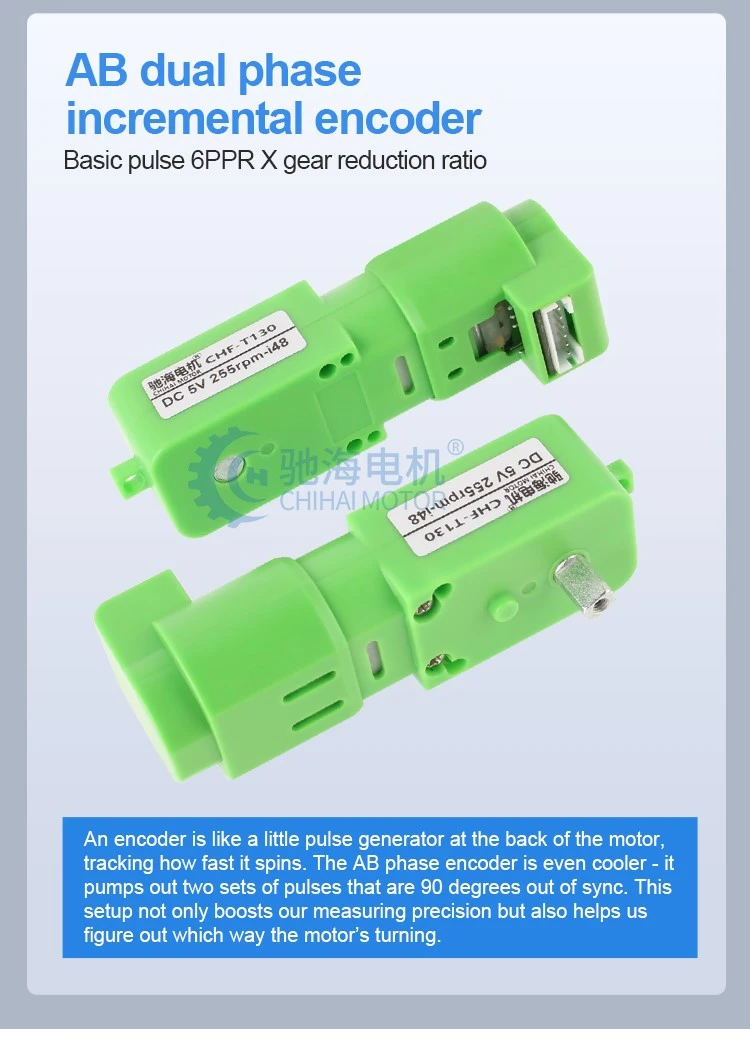
AB dual phase incremental encoder:
Basic pulse 6PPR X gear reduction ratio
An encoder is like a little pulse generator at the back of the motor, tracking how fast it spins.
The AB phase encoder is even cooler - it pumps out two sets of pulses that are 90 degrees out of sync.
This setup not only boosts our measuring precision but also helps us figure out which way the motor's turning.
Detailed Images:
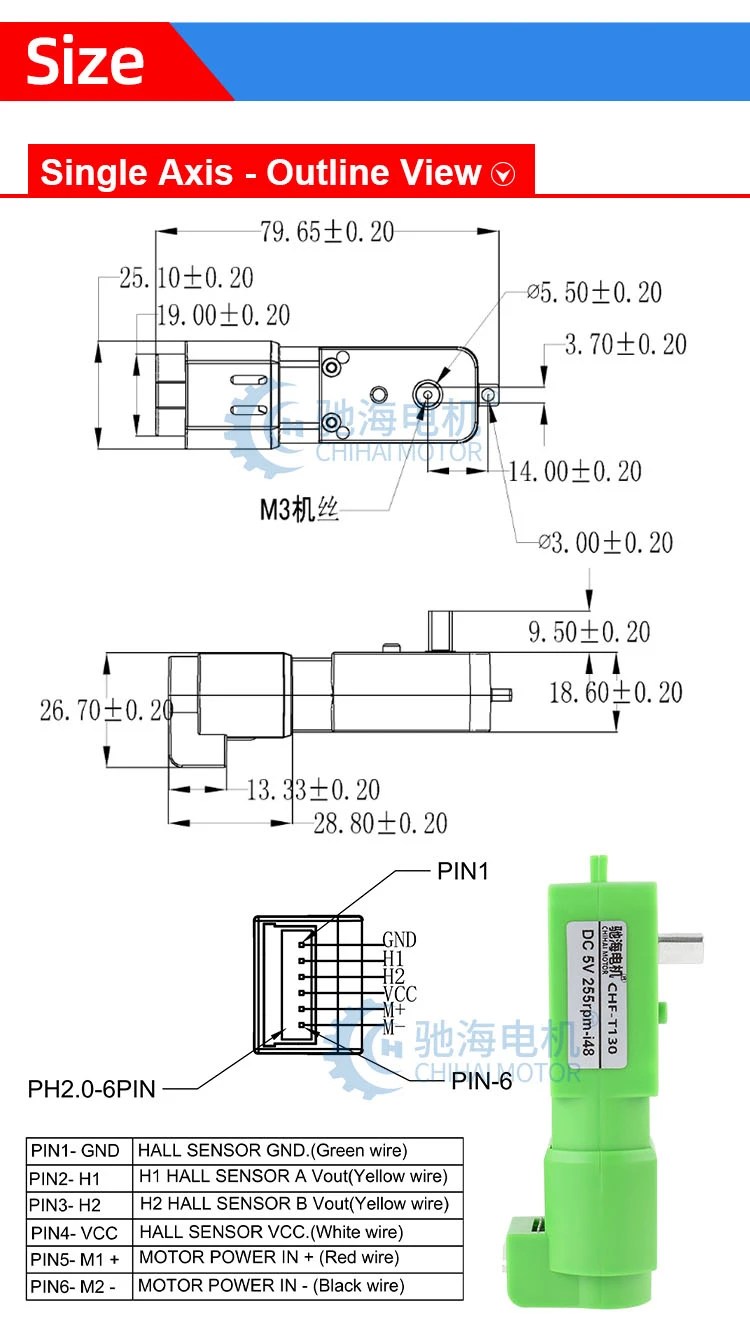
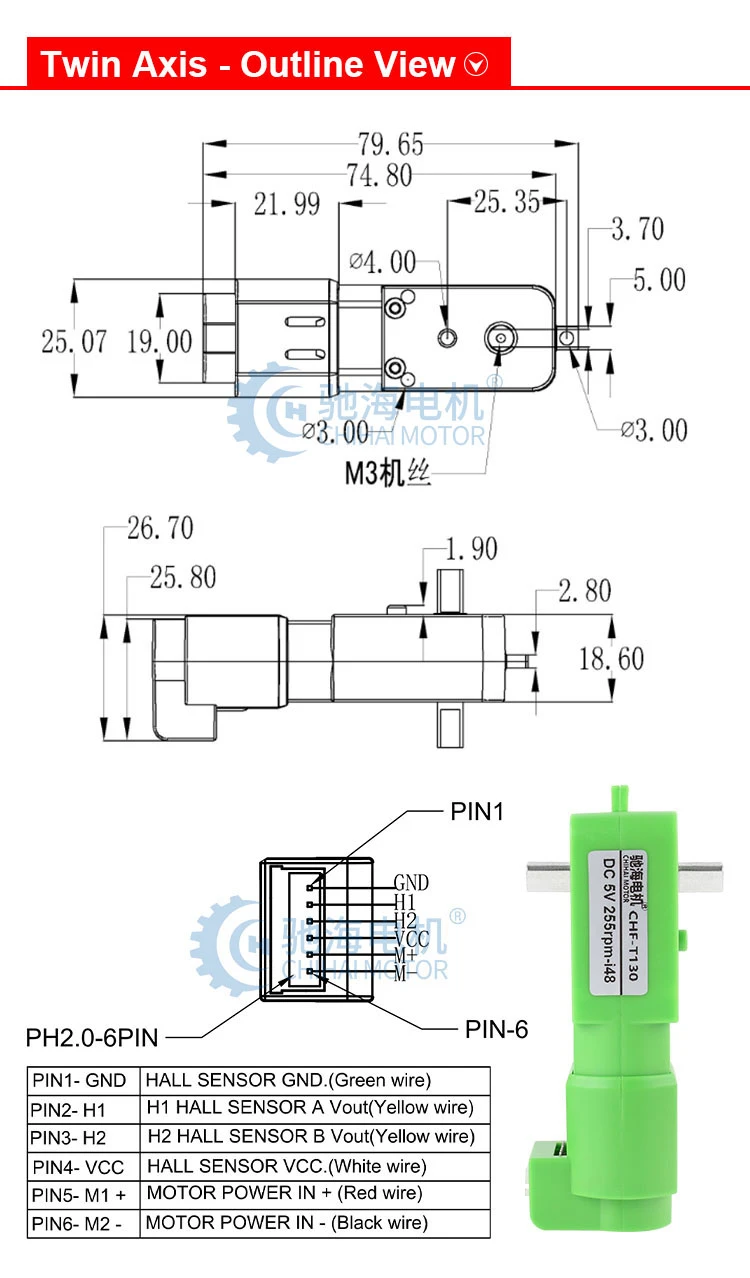
Note: 1.The voltage between V-G is set based on the microcontroller's power supply, typically 3.3V or 5V.
2.The frequency of the square wave from H1 and H2 is influenced by the motor speed and the pole count of the magnetic disc.
3.The voltage between M+ and M- is determined by the motor's operating voltage.
Working principle:
1,Motor speed measurement: The Hall sensor detects the N and S poles of the magnetic disc. We're using the type that senses the S pole. So, every time the Hall sensor picks up the S pole of the disc, it sends out a high-level signal at the output; it sends a low-level signal when it senses the N pole. As the motor turns, the Hall sensor outputs a square wave. By measuring the period T of this square wave, we can determine the motor speed. Let's say our magnetic disc has P poles, and we measure the square wave period as T. The formula to calculate motor speed is: n = 60 / PT
2.,Detecting motor direction: We've got two Hall sensors positioned at different spots in the circuit. Depending on whether the motor's spinning forward or backward, these sensors produce different square waves.
When the motor's going forward, H1 spots a rising edge, and right after, H2 sees a falling one. But when it's reversing, H1 catches a falling edge, and then H2 does the same.

Hot Tags: dc gear motor with encoder tt motor dc5v, China, manufacturers, factory, customized, wholesale, bulk, in stock, Gear Reduction Motor With Encoder
You Might Also Like


Send Inquiry